APF · depth camera
Artificial Potential Field
A 3D field: the goal pulls, obstacles seen by an OAK-D Lite depth camera push, and the drone follows the sum in real time.
How it works → github.com/blar-tw/APF ↗Planners and safety filters for drones in PX4 and Gazebo, and software for the people around them. Heading to ICUAS and AIGP in 2027.
I'm an engineering student drawn to machines that have to think for themselves: robots, drones, and the AI behind them. I learn by building, so most of what I know came from projects, research, and hackathons.
Age ?
How it started: first computer, first code, first robot
2023 · age ?
Hsinchu, Taiwan.
2024 · age ?
Lead coordinator for Hsinchu's high school computer science clubs.
2024 · age ?
Research intern. Drones, ROS 2, PX4.
2026 · age ?
APF, HOLO-DWA and MPC in PX4 SITL, plus D-Guide, a voice-commanded guide drone.
2026 · age ?
DAHacks 5.0, 2nd place with BikeScape. Cal Hacks 13.0 with Orkio.
Now · age ?
Computer engineering, transferring to a UC.
Research · Math 1A Honors · in progress
The planner asks for a velocity straight at the goal, through the wall.
A barrier function h(x) marks the safe set: everywhere h ≥ 0.
The safety filter bends the command just enough to stay inside, and the drone slides along the edge.
But PX4 tracks velocity with lag τ. When α·τ > ¼ the guarantee breaks and the drone overshoots. The project derives that bound with calculus and tests it in PX4 SITL.
Autonomy lab · PX4 SITL + Gazebo
Each one is a full ROS 2 node flying a simulated multirotor through the same kind of obstacle field.
Take the drone apart →APF · depth camera
A 3D field: the goal pulls, obstacles seen by an OAK-D Lite depth camera push, and the drone follows the sum in real time.
How it works → github.com/blar-tw/APF ↗VFH · 2D LiDAR
Every control tick, a polar histogram of obstacle density; fly the most open direction that still heads for the goal.
How it works → github.com/blar-tw/VFH ↗NMPC · CasADi + IPOPT
Re-solves a receding-horizon optimization every tick from LiDAR, sending 3D velocity commands toward the goal.
How it works → github.com/blar-tw/MPC ↗RRT* · global planning
Grows a tree through 3D space, rewires it toward a near-optimal path, and re-plans when the LiDAR map says the route is blocked.
How it works → github.com/blar-tw/RRT- ↗DWA · holonomic
A holonomic take on the Dynamic Window Approach: reactive, LiDAR-driven avoidance for a multirotor that can move sideways.
How it works → github.com/blar-tw/HOLO-DWA ↗APF: Newton — push the object.
WARP: Einstein — curve the space it lives in.
WARP · Riemannian geometry
Obstacles enter a conformal metric that puts every surface at infinite geodesic distance. Collision would need an infinite path. Closed-form, no solver.
How it works → github.com/blar-tw/WARP ↗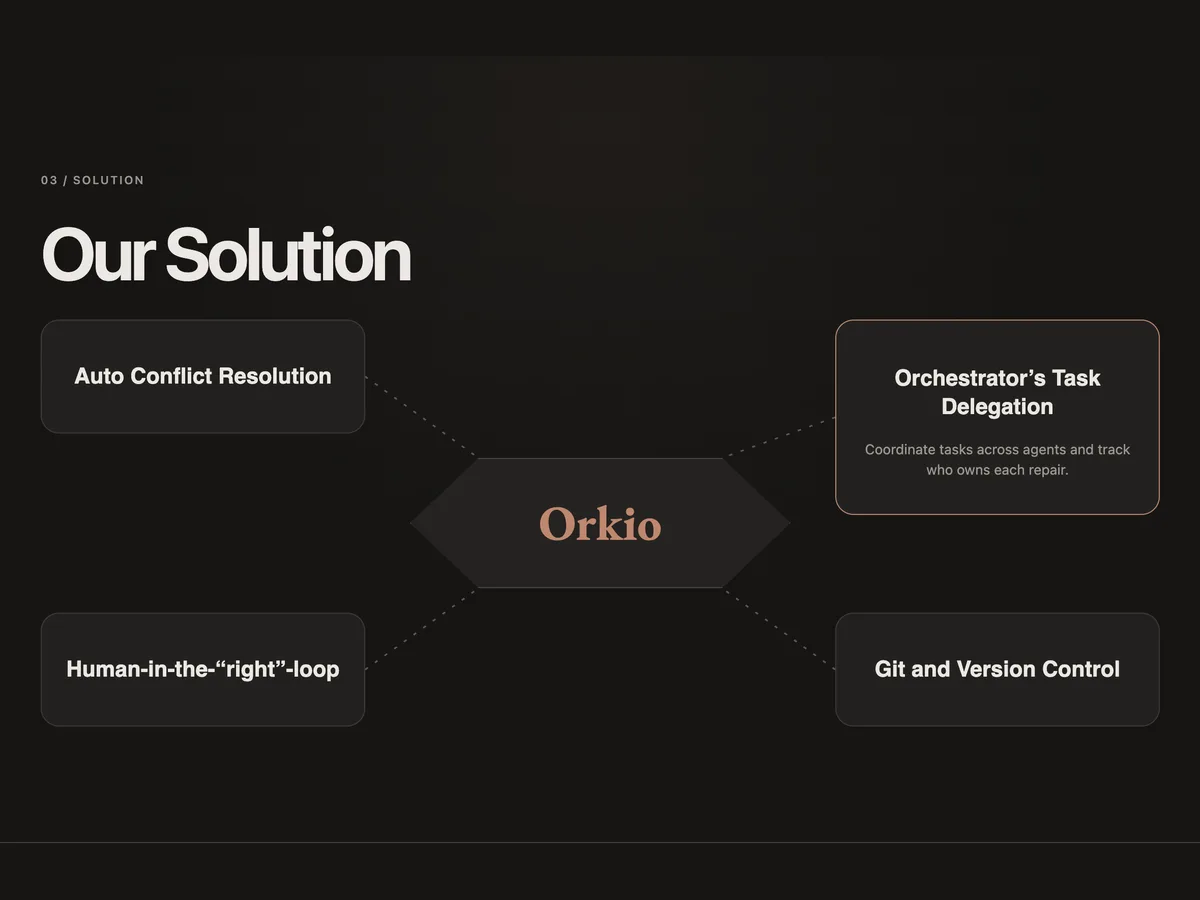
Hackathon · Cal Hacks 13.0 · 2026
A coordination layer for AI coding agents on different laptops. Hooks snapshot each agent’s unfinished work to Git, agents share plans over MCP, and an orchestrator merges the snapshots and runs tests to catch conflicts before they reach main. In a head-to-head build, it took 2 prompts instead of 9 and finished in 10 minutes instead of 16.
TypeScript · Factory Droid SDK · SpacetimeDB · Claude Code hooks · MCP
devpost ↗ github.com/chuddrw/CalHacks26 ↗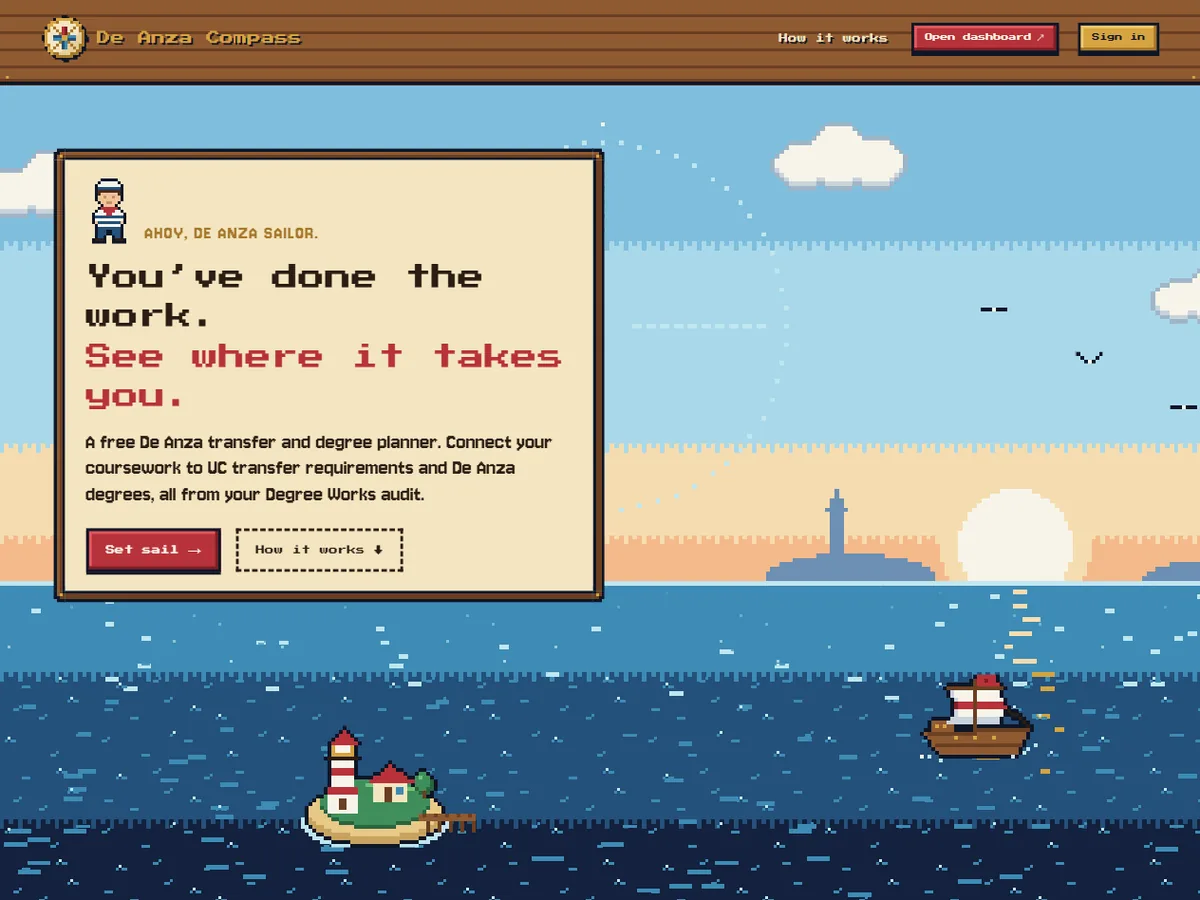
Web app · Live · 2026
A free transfer and degree planner for De Anza students. Upload a Degree Works audit and see what’s left for UC transfer majors (from ASSIST) and which De Anza degrees and certificates you already qualify for, including ones you never applied for.
Next.js · React · Prisma · PostgreSQL · Supabase · Chrome extension
deanzacompass.com ↗Hackathon · 12 hours · 2026
A campus social app for students in their first weeks. Swap cards by QR code, watch your circle grow as an Obsidian-style graph, and keep notes on people you meet. AI suggests the notes; you approve every line.
React · Hono · Postgres · WebSocket
 Safe ↔ Green
Hackathon · DAHacks 5.0 · 2026
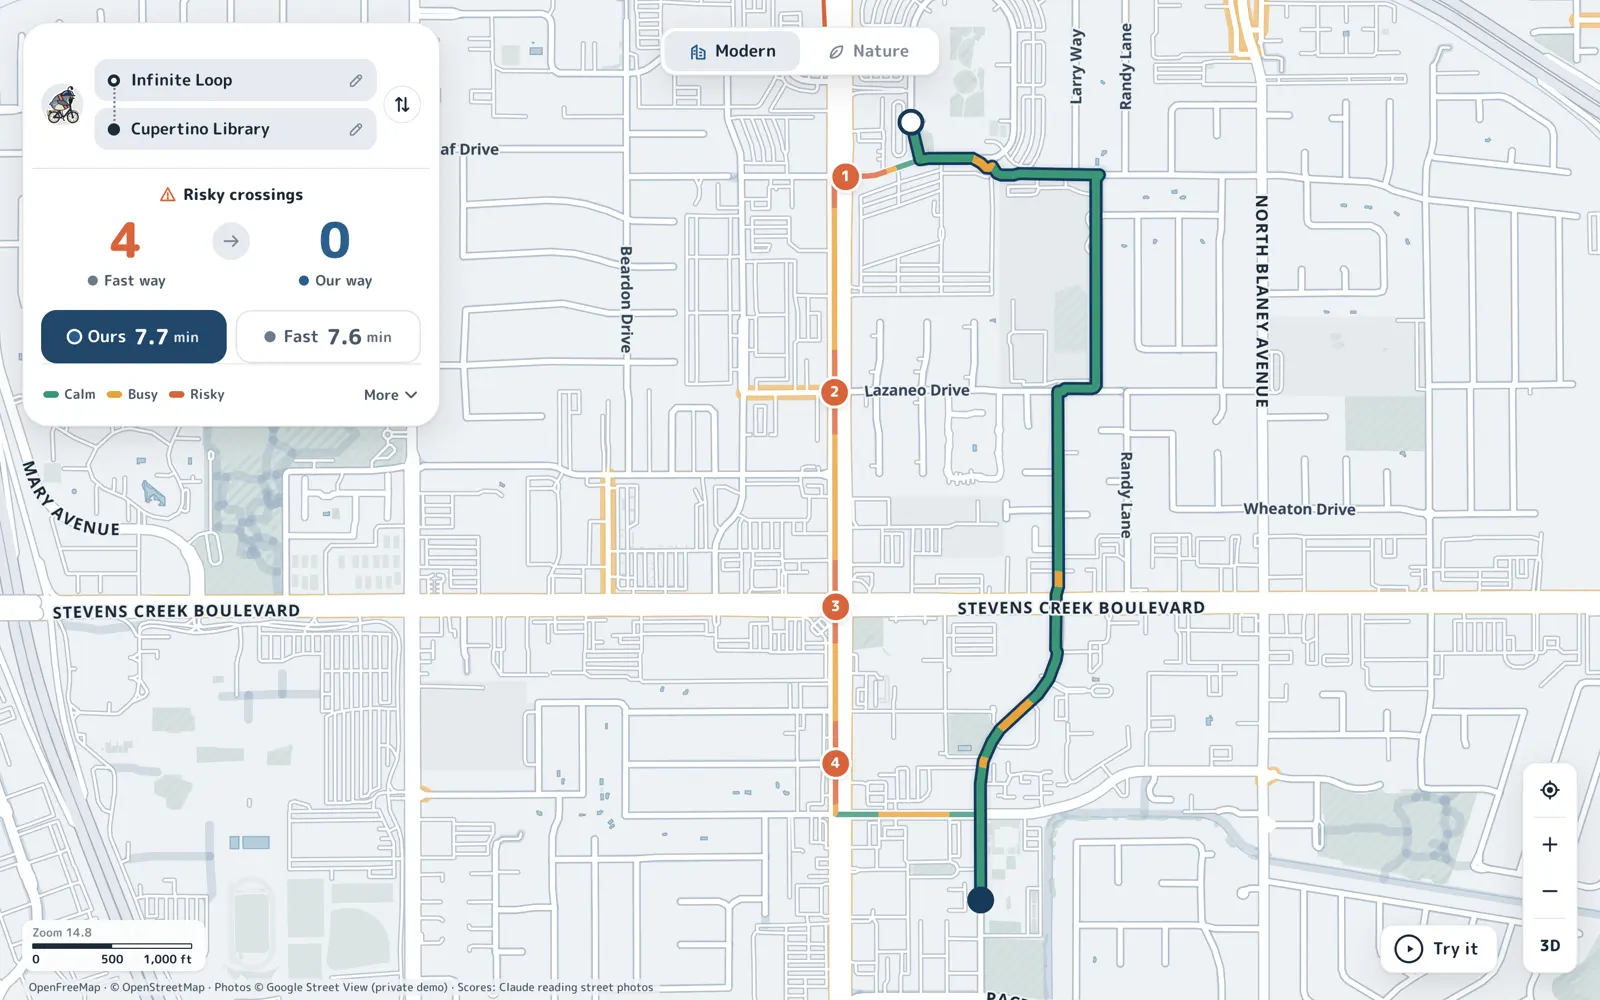
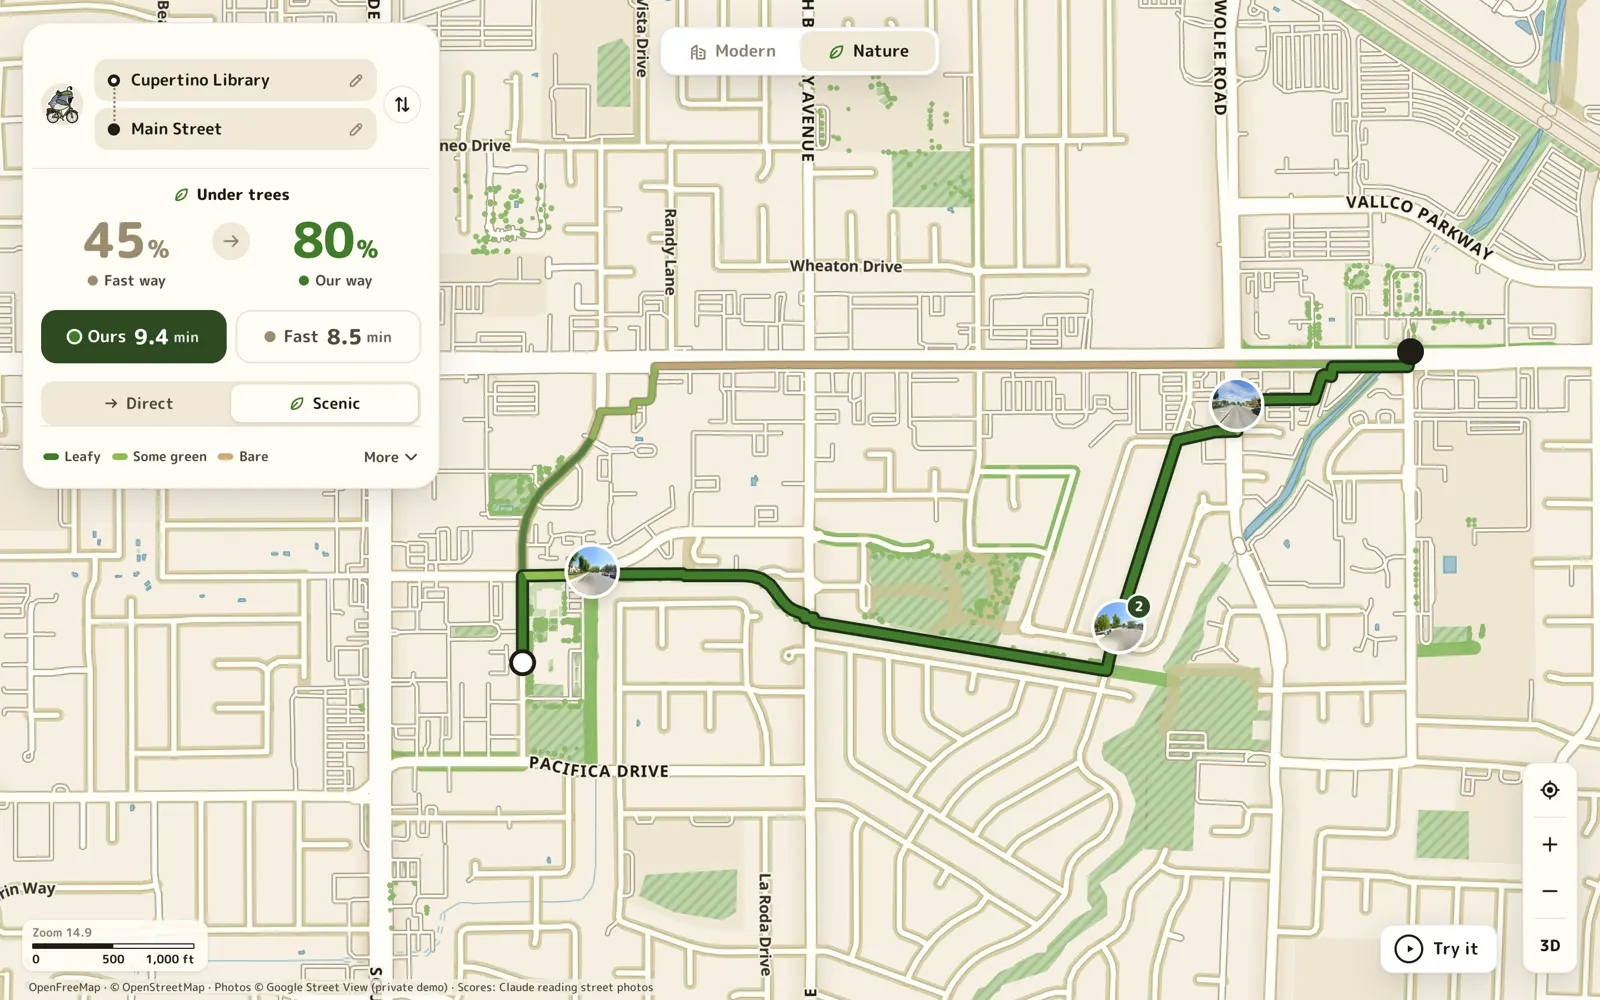
Two bike maps for Cupertino. Every street gets a 1–10 safety score from Street View photos and city data; routing runs Dijkstra on “felt distance,” and real crash records are used only to validate the scores.
Python · Claude Vision · OSM · Dijkstra
github.com/blar-tw/Dahacks ↗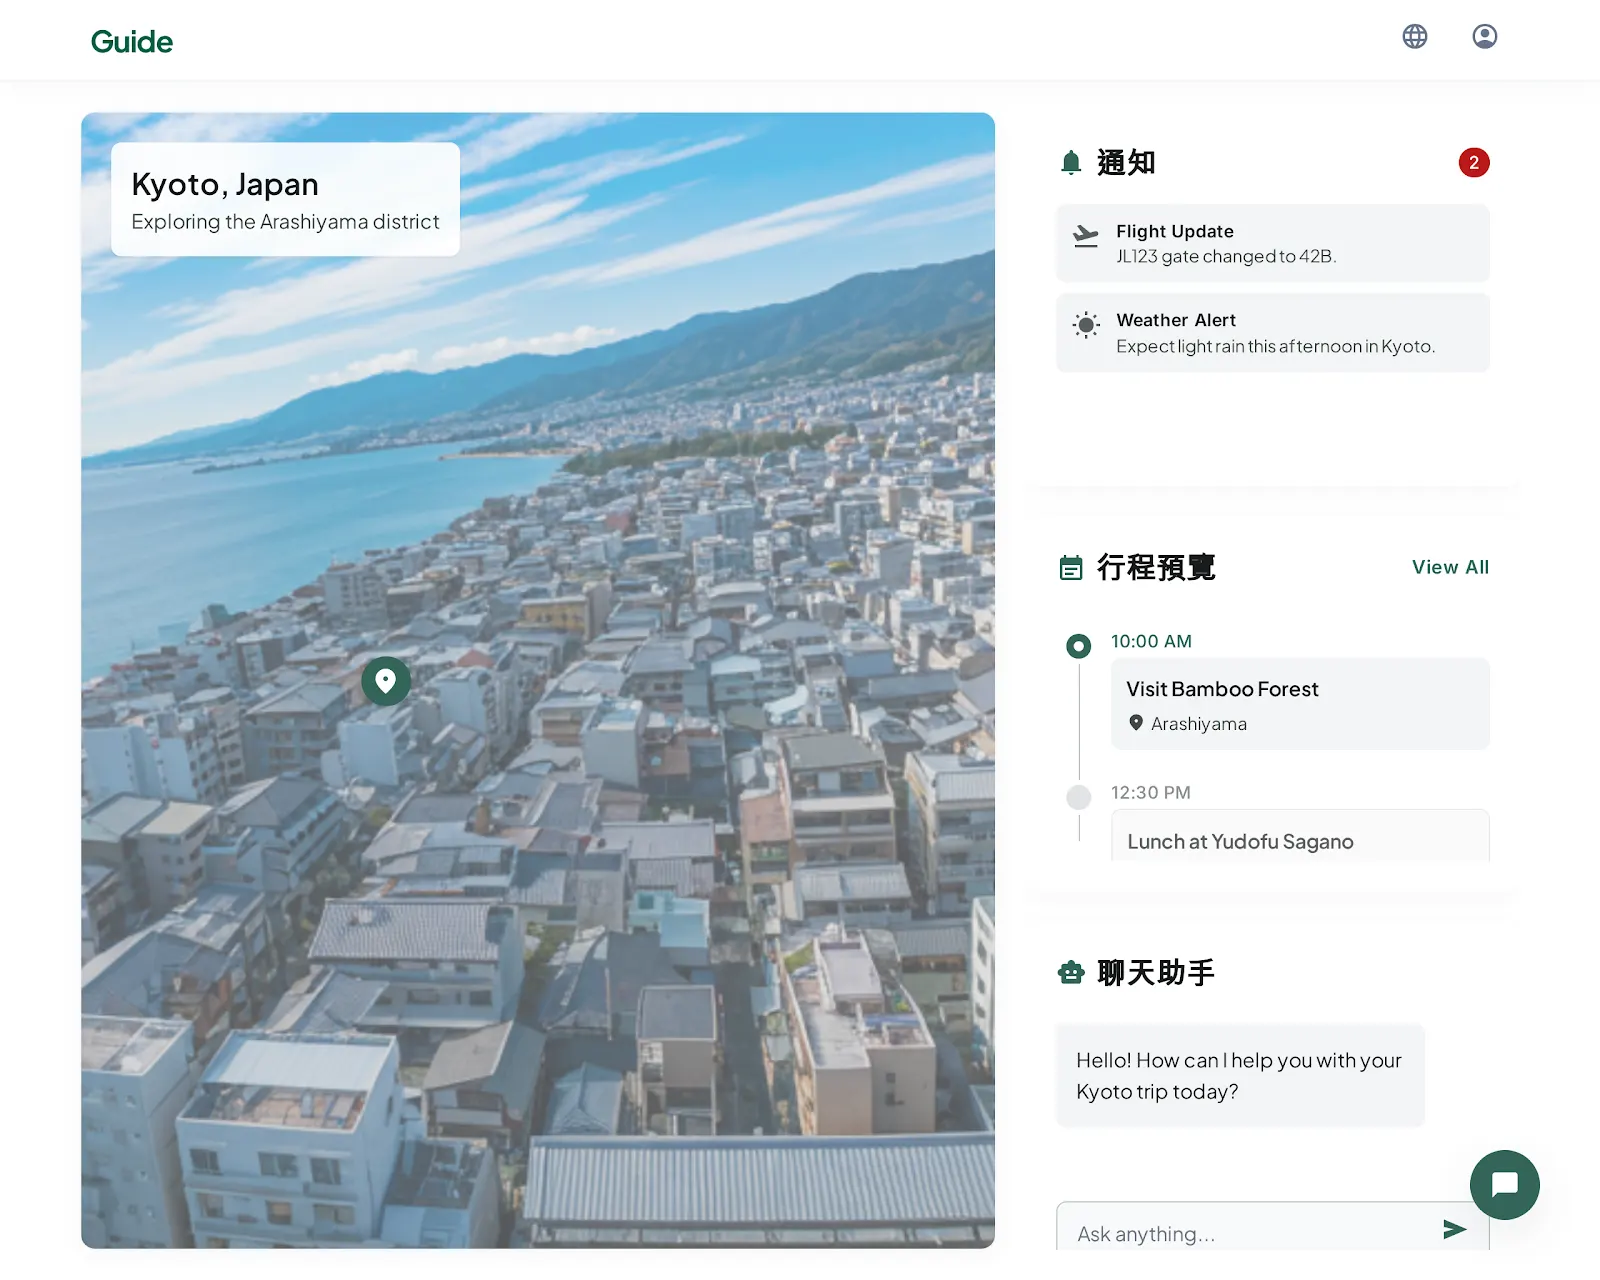
Hackathon · Taipei
A Taipei travel planner that checks lodging against city open data, builds itineraries with RAG, and pushes weather and crowd updates through an AI agent.
repo ↗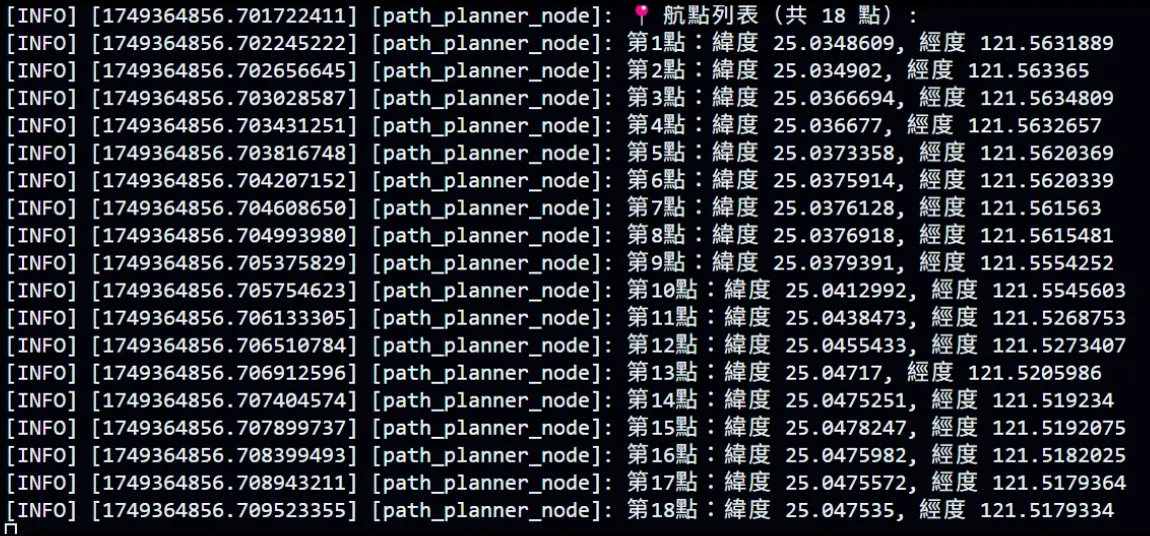
ROS 2 · drone
A voice-commanded guide drone: it geocodes your destination, turns Google Maps walking directions into GPS waypoints, and flies ahead of you.
repo ↗Robotics camp · 2026
Line-following on the BitRacer Pro Max at the TMIRC summer camp, programmed two ways: MakeCode on micro:bit and Arduino on the on-board MCU.
repo ↗Windows · Python
Press a hotkey and Claude reads the problem under your mouse, then shows step-by-step work with rendered LaTeX, code blocks and matplotlib figures.
repo ↗Robots should be provably safe — then useful.
I'm a computer engineering student at De Anza College, planning to transfer to a UC. I work between control theory and software: obstacle avoidance and safety filters for multirotors in PX4, ROS 2 and Gazebo, and apps built fast at hackathons.
Python · C++ · PyTorch · ROS 2 · PX4 · Gazebo · Docker
Looking for research and internship opportunities.